How a mathematical view becomes a figure
Suppose we are looking at the matrix of a map between sums of principal modules on a finite poset. A zero can appear because the map happens to have that coefficient, or because the order forbids any nonzero coefficient in that position. The distinction belongs to the map before we choose a color or a font. It should survive a change of plotting package, a smaller displayed block, or a caption pointing to one entry.
TamerOp records such information in a VisualizationSpec, the prepared description of a mathematical view. The description contains the drawing instructions together with the selected coefficients, labels and any checks performed on the object. CairoMakie and WGLMakie are rendering backends: they turn that description into a figure or a browser scene. Preparing the view may ask a mathematical question, such as the rank of a selected map; drawing the prepared view uses the answer already obtained.
The visualization guide develops the public workflow, and composing figures shows how to bring several views together. Here we follow the information they retain, then look at the preparation and drawing mechanisms that keep it attached to the right objects.
Separate the mathematical request from its presentation
Consider the poset with two elements, $1<2$, over a field $K$. Its principal projective $P_u$ has value $K$ at a vertex $q$ when $u\le q$, and zero otherwise; its maps between nonzero stalks are identities. A stalk here means the vector space assigned to one vertex. A map from $P_u$ to $P_v$ can have a nonzero coefficient only when $v\le u$. Indeed, the image of the generator at $u$ must lie in $P_v(u)$, which is zero unless $v\le u$.
For a map from $P_1\oplus P_2$ to $P_1\oplus P_2$, take
\[A=\begin{pmatrix}1&0\\0&1\end{pmatrix}.\]
Rows name target summands and columns name source summands. The lower left zero is forced, since it would describe a map from $P_1$ to $P_2$. The upper right zero is a permitted coefficient that happens to vanish. The prepared view marks only the forced zero with a dagger, while retaining the original matrix over $K$.
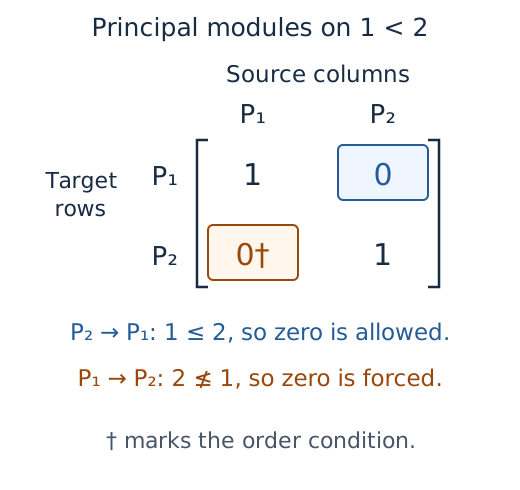
This is a schematic of the selected coefficient matrix. Both marked positions contain the field element zero; the dagger records why one of them must do so. Changing the permitted zero changes the map. Changing the forced zero to a nonzero value violates the order condition and is rejected before drawing.
The preparation routine for an object is called its visual recipe. It first checks whether the object supports the requested view and options, then constructs a specification with graphical layers or child panels. A layer groups one sort of drawing, such as points, paths, polygons, interval data or a literal matrix. Its role may say that an item is selected or belongs to the source of a map. The style translates these roles into colors and other appearance choices at render time, so a grayscale export preserves the same selection and coefficients.
Alongside these layers, metadata records the selected indices, coefficient field, category, degree convention and scope of any computation. In the matrix example it retains the complete selected matrix even when a display limit shows only a block. A map into the zero space has zero rows; a map out of it has zero columns. Retaining both dimensions keeps those cases distinguishable even though neither has an entry to print. Coefficients themselves remain literal text, including fractions and finite field elements, whose colors would have no intrinsic interpretation as real magnitudes.
Reuse source preparation before drawing
For a point cloud, the first question is often which points to join. A graph of $k$ nearest neighbors (kNN) chooses neighbors using Euclidean distance in the full coordinate space; a radius graph joins points whose distance is at most the specified radius, including equality. Preparation shares this computation with sparse ingestion and uses its floating point metric. An activated spatial tree can accelerate the exact neighbor search, where “exact” means no approximate neighbor selection, rather than exact real arithmetic. Without that extension, the fallback retains the required nearest candidates as it scans, avoiding a sort of every distance row. The renderer receives the prepared edge segments.
For example, selecting axes (2,1) swaps the drawing coordinates. It leaves the graph computed from all source coordinates unchanged. Selecting fewer vertices then keeps only edges with both endpoints displayed. These operations occur after preparation: the original edge index and endpoints remain attached to each surviving segment. Supplied graph polylines follow the same edge IDs. Weighted edges retain the full graph's bin limits, so an omitted extreme edge cannot silently change every displayed color.
Repeated requests can share a SessionCache, a store of prepared results used by both ingestion and previews. A graph entry records a copy of the coordinates, the graph settings and the chosen neighbor backend. Comparing the coordinates with that copy detects edits to the input; a matching hash alone would not establish equality. At most four graphs are retained, with the oldest removed when another is inserted. Coordinate projections have a separate limit of four. A lock holds lookup and construction together, so simultaneous requests share the prepared entry. Input coordinates must be changed outside these calls. Arrays returned for display are copies, so editing their metadata does not change a later graph query.
Reuse still requires a pass through the coordinates to establish that they have not changed. Retained graphs occupy space for their edges and neighbor distances, and retained projections occupy space for the source coordinates. Selecting displayed edges may require another scan. When every source vertex is shown, however, a computed graph already has valid endpoints, so the first bounded set of edge IDs can be selected directly. A supplied graph still has to validate its endpoints. A preview with cache=:auto retains no preparation after the call; retaining a SessionCache is the explicit choice to share it. Keeping the returned specification avoids this source preparation altogether when the next request is only to draw the same view.
Preparation and display bounds have different meanings. Before brute force, the requested bound on distance pairs is checked. kNN also checks its directed candidate bound before allocation. Radius construction stops with an error before appending an edge beyond its output cap, both in the fallback and spatial tree routes. A failed construction is not cached as a partial graph. Display budgets subsequently select source indices and report omissions without changing the mathematical input. Point density bins still count the full point cloud.
The shared graph preparation owns neighbor reuse; source preparation owns projection reuse and display identities. The usage section develops the workflow, and the reference owns exact option contracts.
Keep collection identities attached to their numbers
A collection view begins with supplied tables and a declared sample order. A feature table assigns numerical measurements to each sample; distance and kernel tables assign a value to each pair. Preparation checks limits on the number of samples and cells before checking shapes, labels and values, then copies the supplied tables. It does not compute the pairwise values. A FeatureSet retains its original metadata and each column's feature definition, so selecting an entry can explain which mathematical query produced it. A missing entry and a positive infinite distance both need an uncolored heatmap cell, but remain distinct values in the retained table.
The heatmap uses rows for samples and columns for features or target samples. Its floating drawing matrix is separate from the original selected value. Pair tables are checked for exact symmetry. Even if a distance table is nonnegative and zero on the diagonal, establishing the triangle inequality would require further work. Similarly, a kernel matrix is positive semidefinite when $z^T Kz\ge0`` for every real vector ``z$, a condition that symmetry alone does not establish. Neither property is certified by this preparation. A supplied embedding places samples in the plane and retains its method, settings and random seed. Those positions follow the sample order, without asserting that their Euclidean distances equal the entries of the supplied table.
Selection rebuilds a bounded specification from retained data. The same sample index highlights an embedding point and reveals its supplied invariant/source panels. Composite sample views are flattened into their individual panels; no new invariant or source reconstruction runs. Session updates validate first, prepare the next snapshot, and only then commit and notify listeners. Failed updates preserve the previous selection. Closing releases collection inputs and witness references while leaving an exportable final snapshot.
For a pair of persistence diagrams, a retained matching records the interval assignments used to witness their comparison. It is addressed by ordered sample IDs because reversing a matching requires reversing those assignments. Opening a retained witness creates an independent matching inspector. Computing a new one is an explicit request for the selected pair, delegated to the existing matching implementation; it leaves the supplied matrix unchanged. The browser closes an embedded pair view with the collection, while a matching session created by the caller remains independent. Exploring a collection therefore does not start computations for every pair of samples.
The collection builder owns value semantics and preparation; the session owns selection and lifetime. The guide develops the example, and the reference spells out shapes, budgets and matching options.
Align queries before subtracting observables
Before subtracting the dimensions of two results, we need to decide which parameters correspond. A comparison therefore receives named results and an alignment of their queries. When queries use finite vertices, each result gets its own vertex list: vertex 3 in one poset need not describe the same parameters as vertex 3 in another. When queries use original parameters, each encoding's classifier, the map assigning parameters to finite labels, finds the appropriate vertices. Dimensions can then be read without constructing structure maps.
A rank request fixes a source parameter and computes the ranks of its maps to the target parameters, forming one row of a comparison table. For encoded modules, preparation checks comparability in the original parameter order as well as the finite poset. Two incomparable parameters can land in one coarse fiber; their equal labels do not create a forward map. Unrepresented points and unordered pairs remain distinct masked values through subtraction and rendering. The live session retains one row per result, so selecting another target or baseline reuses the computation. A changed anchor replaces that bounded retained row. For a lazy encoding, the first nontrivial map calls encoding_module, which materializes the finite representation. The viewer bounds rank-table work, not the owner's module-construction cost.
Ordinary diagrams supply another implementation of the same observable contract. Dimension counts intervals containing a parameter, and rank counts intervals containing both ordered endpoints. These sums use all grouped records with their multiplicities and endpoint conventions, even when the drawing budget omits some groups. A bar that survives the computation cutoff supplies no information beyond the recorded query window. The drawing clips it to the known coverage and marks that end as censored, meaning the computation ended before its death was determined. The stored interval remains separate from this drawing choice.
Subtracting the baseline's integer value from the case's value now compares the same declared query. For example, a difference of one in rank says that the case's image has one more dimension than the baseline's. It does not identify a vector in that extra dimension, provide a common basis, identify coefficient fields, or match bars. Selected matrices remain separate literal panels so that their own bases and fields stay visible. For floating point coefficient fields, the rank routine is reevaluated at half and double the declared tolerances. This modest sensitivity diagnostic is printed with its limitations; it is not an exactness certificate. Authored construction and approximation descriptions remain separate from provenance recorded by the computational owner.
Compose semantic views before resolving their positions
Suppose we place a source cycle beside its barcode and draw an arrow between them. Moving the barcode panel should move that end of the arrow, while choosing a different interval should require a different mathematical selection. To make this distinction possible, composition takes prepared leaf views, meaning individual panels with no further child panels, and gives each a stable name. An overlay draws several such views in one axis after comparing their declared coordinate context and visible windows. Rendering delegates each child's layers back to its own drawing path, so interval endpoint decorations, source labels and scalar ranges retain their meaning. A shared legend includes repeated labels once when their graphical meaning agrees, and rejects a label that would name conflicting encodings.
The coordinate context names the domain, units, parameter orientations, coefficient field and degree. Its provenance identifier records which source or construction the caller says the data came from. Known object metadata constrains the caller's declaration. Equal identifiers express a declared correspondence, not a recomputed theorem; an intentional comparison records its mismatches and prints its explanation. Independent panels need no common domain. Explicitly linked axes do, while linked scalar colors additionally require the same quantity and colormap. Preparation scans finite samples for a common range without altering the stored values.
An annotation's endpoint is an anchor: a panel name together with a choice of an object or a position in that panel. For a source cell, the anchor uses retained geometry to find that cell; for an interval, it uses the original member ID, even when equal bars share a displayed row. A matrix anchor names the actual coefficient label. Preparation checks that the selected item is shown, rejecting anchors to omitted data. A coordinate supplied by the author can instead explain a feature of the picture. Such annotations use a visibly different style from a checked mathematical correspondence.
The ordinary cycle connector makes a narrower, checkable claim. It requeries the selected interval representative and checks its field, source identity, parameter and coefficient vector against the supplied cycle. This computation uses the recovery of cycles on original cells described in the source representative account. It does not solve a new representative optimization or identify a canonical geometric hole. Composition and render validation repeat this check, so mutated mathematical storage cannot silently retain a stale solid arrow.
At render time, each data anchor passes through its own axis transformation to obtain a position in pixels for the whole figure. This common coordinate system is what permits an arrow to cross between panels with different axes. A panel or figure anchor instead uses normalized coordinates within its box, and a matrix anchor uses the measured box of the printed coefficient.
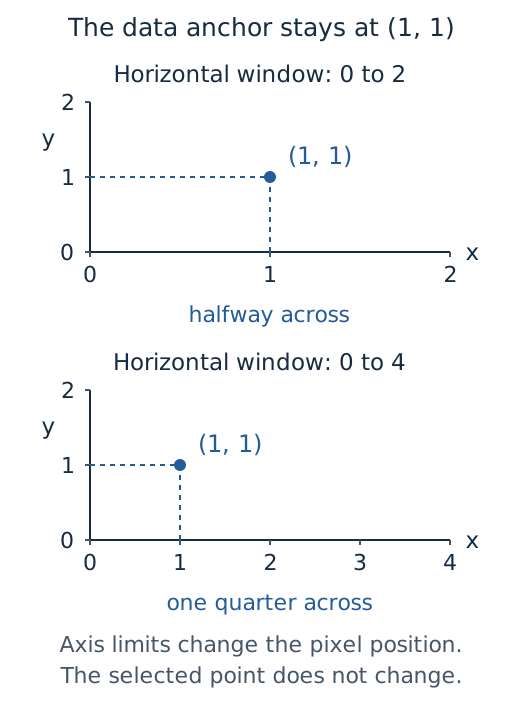
In this schematic, widening the horizontal window changes where the same point appears. The connector must follow the new pixel position. The implementation therefore listens to changes in both the viewport, the panel's rectangle on the screen, and the camera projection that transforms its data coordinates. Listening only to axis limits can read the preceding camera transformation, before the new one has been applied.
Annotations are drawn in a transparent scene placed after the panel scenes, so their strokes appear above panel backgrounds in both WGL and Cairo. A light halo behind text keeps signed weights readable over a scalar background. Curved connectors use a quadratic arc with a bounded bend parameter; brackets and highlights use the same resolved endpoints. If an endpoint leaves the visible data window, the annotation disappears until that endpoint is visible again, rather than acquiring a different mathematical endpoint at the window edge. The drawing uses Makie's coordinate spaces and layout observables to keep those positions current.
Static HTML export prepares a fixed picture of the composition. Cairo renders the complete selected composition to SVG; the export embeds that vector scene and its textual interpretation in one responsive HTML file. A labelled scroll region preserves the SVG's intrinsic size on narrow screens, so scientific labels remain readable and panels and connectors retain one coordinate frame. Reopening the file needs no running Julia process or remote resource. Live WGL interaction with axes remains available while Julia is connected. Saving mathematical objects independently of their figures uses the IO operations.
Preparation is linear in the retained layer and annotation counts, apart from requested checks of source correspondences and scalar scans. Rendering has one reactive endpoint per anchor and an arc sampled at a fixed number of points per arrow. No search over every source pair, decomposition or new homology computation is introduced by layout.
Prepare signed contributions before drawing
A signed rectangle measure represents an observable as a sum of contributions from rectangles, each with an integer weight that may be positive or negative. For a rank query at an ordered pair of parameters, preparation checks which rectangles contain both parameters, respecting their boundary conventions. It compares endpoints in their original coordinate types and sums weights with arbitrary precision integers, so drawing precision and machine integer overflow do not alter that sum.
The corresponding rule for a cumulative point measure is different: an atom at $a$ contributes to a query at $q$ exactly when $a_i\le q_i$ in every coordinate. The set of such $a$ is the lower orthant at $q$. A summary over a declared family of finite intervals instead tests inclusion of finite label sets. These tests recover different observables, even though their signed contributions can use the same graphical symbols.
The query sum is formed before selecting terms for drawing. Consequently a small display budget or clipped window cannot change the reconstructed value. Input IDs and full endpoint pairs remain attached to the records; a selected term can replace the final budgeted entry without losing its identity. Infinite deaths remain infinite in those records, while the drawing marks their clipped positions explicitly. A supplied background of dimensions or Euler characteristics must name its source and share the input's axes and units before its samples are combined with the signed symbols. The Euler characteristic is the alternating sum of homology dimensions at the chosen parameter.
For rectangle smoothing, let $\varepsilon$ be the supplied vector of nonnegative coordinate shifts. Preparation subtracts it from each rectangle's upper endpoint and checks whether any part remains under that rectangle's boundary convention. Testing the smoothed rectangle at a pair $(s,t)$ is then the same as testing the original rectangle at $(s,t+\varepsilon)$. This explains why the independent observable check uses the shifted target. The displayed signed prominence multiplies each remaining side length by the sign of the weight; the absolute weight is retained as the point's multiplicity. These constructions follow Botnan, Oppermann and Oudot, §6.2; they do not perform density convolution or introduce an arbitrary importance score.
One optional callback evaluates the original observable independently. Its answer and the reconstructed answer are retained separately, including when they disagree. Term and view changes in a live session reuse that answer; changed query or smoothing requests a fresh one. Updates build a candidate snapshot before committing it. Failed validation preserves the old state. The contribution scan visits each retained term once and stores one record per term; coordinate precision and containment of finite label sets determine the cost of each test. Input validation also checks the supplied axes or interval family. Drawing is bounded separately. Preparation requires neither a full rank tensor nor a new finite encoding. Inversion algorithms belong to the signed measure implementation; the renderer only receives the resulting semantics.
Resolve storage conventions before drawing an arrow
A resolution replaces a module by a sequence of simpler modules and maps whose exactness relates that sequence back to the original object. In the resolution guide, the diamond example has one, two and one principal projective summands in degrees zero, one and two. These are summands of the resolution terms. They are not a decomposition of the resolved module into persistent classes. A separate support panel therefore names the term and selected principal summand that it depicts.
Projective differentials run from degree k to k-1, whereas injective differentials run from k-1 to k. The selected degree consequently marks a source column in one view and a target row in the other. A single step upset presentation stores its matrix transposed relative to that display convention. The preparation step normalizes these cases; the renderer sees only target rows and source columns. On the injective side, the principal module $I_v$ has value $K$ on the downset $q\le v$. Its socle is the copy of $K$ at its terminal vertex $v$. Evaluating a map at the target summands' terminal vertices recovers the coefficients between these principal injectives.
For source label u and target label v, the principal summand coefficient is allowed only when v ≤ u, on either side. A forbidden nonzero is rejected. The displayed forbidden zeros receive a dagger and a separate semantic role; permitted zeros retain ordinary coefficient text. At a selected finite vertex, preparation restricts the matrix to active summands, preserving their global IDs. An upset presentation produces a cokernel, a downset copresentation a kernel, and a fringe map an image. The visible construction and selected dimension follow that distinction.
The view in the grade plane accepts a supplied order embedding: coordinates whose coordinatewise comparisons agree with the finite poset's order. It checks that agreement in the supplied coordinate type before converting positions to floating point, and rejects distinct grades that collapse to one displayed point. Positions chosen to lay out a Hasse diagram, which draws the cover relations of the poset, need not have this property and are not used as grades. The counts still describe summands in the finite category: RIVET's Betti convention concerns an ambient minimal free resolution and supplies mathematical context, not an automatic identification or an algorithm dependency.
Checking exactness, minimality and termination
A table of stored generators can be made by counting labels. Certifying a resolution requires examining its maps, so the default view leaves minimality and termination unchecked. Requested verification revisits the whole stored prefix, including the augmentation onto the resolved module or the coaugmentation from it.
The exactness check is ordinary linear algebra at each finite vertex. For consecutive maps $U\xrightarrow{A}V\xrightarrow{B}W$, the equation $BA=0$ places $\operatorname{im}A$ inside $\ker B$. Rank-nullity then gives
\[\operatorname{im}A=\ker B \quad\Longleftrightarrow\quad \operatorname{rank}A+\operatorname{rank}B=\dim V.\]
Both the zero composite and the rank equation matter. Equality of the two numbers alone would not put the image inside the kernel. The augmentation must be surjective, or dually the coaugmentation injective. Verification also checks that the stored term maps use the declared principal summand bases and that each stored differential agrees with its extracted coefficient matrix, so these rank calculations refer to the same maps throughout.
Minimality uses each map's actual kernel or image. For a projective term at vertex v, let D be its map to the preceding object and let D_old retain columns born strictly below v. If b summands are born at v, minimality requires the following equality at every vertex:
\[\operatorname{rank}(D)-\operatorname{rank}(D_{\rm old})=b.\]
The rank difference is the number of independent images contributed by the new columns after quotienting out the span of the old ones. Equality to $b$ says that all $b$ are needed: no nonzero combination of new generators has its image in the span of the older images. Requiring this at every vertex is the usual condition that the kernel lie in the radical of the projective term, where the radical at $v$ consists of coordinates generated strictly below $v$.
Dually, an injective extension is essential when every nonzero submodule meets its image. For these finite modules this is equivalent to containing the socle, the sum of the simple submodules. At $v$, the relevant socle coordinates are the summands ending there. Write $D$ for the matrix of the incoming map at $v$, and let $E_{\rm soc}$ consist of those standard basis columns. Containment of the socle in the image of $D$ is then checked by
\[\operatorname{rank}[D\ E_{\rm soc}]=\operatorname{rank}(D).\]
These checks work at the last retained term too. Absence of a next differential alone is insufficient to certify minimality. A nonzero terminal kernel or cokernel marks a truncated prefix; a zero one certifies termination. The view never pads uncomputed degrees with zero rows. For exact coefficient fields, rank and equality use arithmetic in that field; numerical fields retain their declared tolerance semantics.
A supplied basis change undergoes a separate check. If $S$ and $T$ express the new source and target bases in the old coordinates, respectively, then a new source coordinate vector $x$ represents the old vector $Sx$. Applying the old matrix gives $ASx$; expressing the answer in the new target basis gives $T^{-1}ASx$. Thus the new coefficient matrix is $B=T^{-1}AS$, and the check is $AS=TB$. Both changes and their inverses must obey the grading and be invertible over the declared field. This verifies the selected incidence map in its new coordinates; it does not compute a minimal presentation or change a whole complex. Adjacent differentials and the augmentation still use their original coordinates unless an independently constructed object supplies them.
Retained work, drawing costs and export
A multiplicity table allocates an array indexed by degree and vertex, without performing elimination. An incidence view selects one differential and, optionally, the block active at a single vertex. Explicit verification traverses all retained degrees and finite vertices and performs ranks; displaying only a few rows does not reduce that verification scope. A view of a large sparse resolution may spend most of its time on dense stalk matrices or on inverting the supplied basis changes. Matrices in specification metadata are copied so that later display edits cannot mutate the resolution. The graph and separate support panels add their own layout and scene costs; limits on support panels state how much is shown.
Resolution construction happens before these recipes are called. A caller can retain a specification and draw it again with another style or backend; the recipe keeps no implicit store of previous results. Rebuilding with verification recomputes the checks, avoiding stale claims after mutation. A different mathematical selection requires a new specification. Live inspection sessions have their own selection and lifetime contract; loading WGLMakie does not add callbacks to static resolution views.
Backends register render and save functions through optional package extensions. An explicit backend must be active. Automatic inline rendering prefers WGL in a notebook when available, then Cairo; saving prefers an available static backend. Explicit filename exports use their declared format, while the simple export named by a directory and stem returns the actual path, backend and format. Both backends use the same matrix and layout routines, keeping literal coefficients and annotations consistent with the prepared object.
Batch drawing without changing the question
A layer can contain thousands of edges while sharing one color, line width and meaning. The renderer stores their endpoints in a single segment plot. Each pair remains independent: batching does not join the end of one edge to the start of another. A barcode similarly expands the supplied multiplicities into their original rows, then draws those strokes together. The decorated barcode view groups colored strokes, foreground endpoint markers and endpoint labels separately. Open marker centers and selected marks retain their order within the array of markers. Diagram markers likewise share a scatter plot, while annotations retain their measured layout and exact interval identities. Connected paths retain their internal joins; separators between paths prevent spurious connecting edges. Closure edges remain explicit.
Diagram annotations are arranged after the axis limits and tick orientation are established. Arranging them against temporary limits would repeat the collision layout when those limits change. Subsequent resizing still updates their measured positions, with their mathematical anchors unchanged. The renderer measures the rectangle occupied by each printed string, then places labels in pixels relative to the axis. A bounded, deterministic search prefers positions that avoid earlier labels and data markers. Existing offsets are reused when they remain clear after a viewport change. The two coordinate bounds are applied independently, including at corners. Labels are placed one after another without revising earlier choices, so a dense view can still have overlaps or crossing leader lines, the segments joining a label to its point. A more expensive search might separate them. Every displayed interval keeps its label.
One text plot holds all labels and one segment plot holds their leaders. Leaders end at the measured label rectangle and leave a gap around the data marker. Neither layout nor leader clipping changes the interval's data coordinates. Projection and viewport changes update these two plots directly, without a second hidden annotation scene or a connector subplot for each label. The arrays of text and coordinates still grow with the number of displayed labels.
Planar polygons use Makie's vector polygon recipe when their outlines can be drawn together. Outlined polygons with overlapping bounding boxes retain the supplied painting order, because drawing every fill before every outline could expose an earlier boundary. This conservative choice can leave some concave, disjoint polygons unbatched. Spatial faces are triangulated in the plane of greatest projected area and collected into one mesh with separate vertices per face. A vertical face is therefore not lost by projection onto the horizontal plane, and adjacent faces do not acquire artificially smoothed normals.
Text is batched with a position, alignment and pixel offset for each label. Halo text retains label order, including when labels overlap. WGL draws its native outside stroke with a uniform width; Cairo interleaves a background stroke and foreground glyph for each string. WGL cannot save a vector of text stroke widths in its browser scene. An exact coefficient table uses one text plot and one layout anchor. The measured extents of printed text determine the maximum width of each column and height of each row. Matrix entries keep the monospace font and literal strings such as 1/3; row and column labels keep their basis roles. A composition connector follows the selected coefficient's position as the layout resizes, without requiring a separate plot or layout block for it.
These mechanisms use the dependency's segment, polygon and text recipes. Batching reduces the number of scene objects and the updates they need as a view changes. Arrays of coordinates and text still grow with the displayed data; triangulation, font layout and exported geometry still have to be computed. The renderer keeps no geometry cache shared across figures. The caller owns a retained specification or figure, and closing a linked inspector releases its session resources.
Display budgets act before rendering. For example, matrix_limit selects a displayed block while retaining the complete inspected matrix, and max_intervals limits visible interval groups while retaining their identities and exact endpoints. Reducing scene objects never silently removes entries or changes a mathematical query. A prepared specification draws all its supplied layers; it is not an instruction to recompute a cheaper mathematical answer.
The source boundaries are specification types, request/specification validation, resolution preparation, render/export dispatch, and shared Makie rendering. The executable guide develops the mathematical example; the reference owns keyword contracts.
Coordinate sections and shared scales
A ScalarField stores supplied scalar samples on a Cartesian grid. Each array dimension follows one declared coordinate, with an optional final dimension for layers such as successive landscape functions. Choosing plane (3,1) puts coordinate 3 horizontally and coordinate 1 vertically; all other coordinates stay at their selected values. The prepared matrix has rows along the vertical coordinate and columns along the horizontal one. The common renderer transposes it once for Makie's convention, where the first index follows the horizontal coordinate.
For example, suppose a three coordinate array has shape $(2,3,4)$. Fixing its second index at $j$ and choosing plane (3,1) produces a matrix with two rows and four columns, whose entry in row $i$, column $k$ is the original sample $V[i,j,k]$. This explicit correspondence matters on an asymmetric grid: an extra transpose can otherwise produce a plausible picture of the wrong plane.
A comparison accepts fields only when coordinates, labels, units and ordered layer identities agree. That input declares a pointwise correspondence; it does not establish a module isomorphism. A baseline difference is formed only where both samples are finite. The color range is scanned over all supplied samples and layers, then reused across selections and planes. Signed data require a symmetric range around zero and a diverging colormap. A manual range follows the same signed contract. Field IDs and layer labels remain in each panel, while the values of the fixed coordinates and selected value are visible without browser controls.
An optional contour is a level curve of a specified interpolation between the samples. Each grid rectangle is split along its southwest to northeast diagonal, and each resulting triangle receives the affine function agreeing with its three vertex values. An edge contributes a crossing when its lower endpoint value is at most the requested level and its higher endpoint value is strictly greater. This half open convention specifies what happens at an equal vertex value. A triangle with an unavailable sample is omitted; a triangle constant at the requested level has no crossing curve to draw. These contours describe this interpolant, so their appearance alone does not certify the support boundary of a module. Contour colors and line styles are derived from their numeric levels, so a level retains its appearance when other levels are added or removed. Panel axes scale independently to keep strongly unequal coordinate ranges readable; their ticks retain the declared coordinates. The segment layers reuse the normal renderer and retain their numeric levels. No surface in three dimensions or isosurface is inferred from a finite poset without declared coordinates. Such a poset continues to use its graph view.
Preparation costs one global scan for the shared scale and work proportional to the selected plane samples for each redraw, multiplied by the number of requested contour levels. A session caches the scale unless the baseline or normalization changes. It limits the total panels to twelve and charges contour levels against the budget for displayed cells. Input copying is explicit; no rank, barcode or generalized rank computation occurs during a field selection. The landscape adapter account explains how a sampled line family obtains valid ambient coordinates before entering this pipeline.
See the bibliography.