Exact matching distance in a finite window
Two modules can differ in how their classes continue as both parameters increase. To compare them along a line, restrict their spaces and maps to that line and compute the resulting barcodes. The bottleneck distance chooses an assignment of intervals that minimizes its largest endpoint cost, allowing a finite interval to be discarded at half its length. Matching distance asks how large this comparison can become as the line varies, with a weight that accounts for its direction. The finite encoding introduction describes the retained modules to which we apply these restrictions.
matching_distance_exact_2d computes the supremum, or least upper bound, of weighted bottleneck distances over all lines of positive slope, with both slice barcodes clipped to the same finite rectangle. The line geometry and optimization use exact arithmetic. The default answer converts the resulting optimum to Float64; requesting a witness keeps the exact value together with a line and interval assignment attaining it.
import TamerOp as OP
const OA = OP.Advanced
opts = OA.InvariantOptions(box=([xmin, ymin], [xmax, ymax]), threads=false)
d = OP.matching_distance_exact_2d(encM, encN; opts)
Here encM and encN are existing encodings; xmin, ymin, xmax and ymax specify their common viewing rectangle. A complete construction appears below. The two encodings must use the same classifier, the assignment from parameters to finite labels, and the same finite poset. An omitted window is inferred by encoding_box; choose it explicitly when it is part of the mathematical question. :L1 with :lesnick_l1 and :Linf with :lesnick_linf give the same weighted quantity. Here normalize_dirs chooses the direction normalization and weight chooses its corresponding weight; changing them together preserves the weighted comparison. The API rejects other pairings.
Retain and inspect the witness
A scalar gives the optimum but leaves its cause unexplained. Keeping a witness lets us examine a line where the optimum occurs and the interval costs responsible for it. Use the same compatible encodings and opts as above:
result = OP.matching_distance_exact_2d(encM, encN; opts, witness=true)
OP.describe(result)
OA.slice_query(result) gives a basepoint, direction and weight. Its line is basepoint + t * direction; the endpoints in OA.matching_witness(result) use that same parameter t. Consequently, weight times the largest pair cost is the exact windowed answer. The optimizer retains its exact endpoints even at a cost switch, a line where two possible matching assignments have equal cost and exchange which one is preferable as the line moves. The displayed line uses floating coordinates; rounding that line and asking a new query is not the definition of its witness.
using CairoMakie
OP.visualize(result)
Read the panels together: the parameter window locates the common line, the barcodes show its restrictions, the diagram draws the chosen assignment, and the cost panel identifies its largest costs. A missing partner is paired to the diagonal at half its finite interval length. The figure retains separate member IDs for repeated intervals. Equal members and tied costs can leave more than one optimal assignment; the returned deterministic choice does not establish uniqueness or identify source cycles. For a small calculation with a predicted answer, follow the individual interval assignments in the matching recipe. Its prepared comparison distinguishes repeated copies, a deletion to the diagonal and an essential pair.
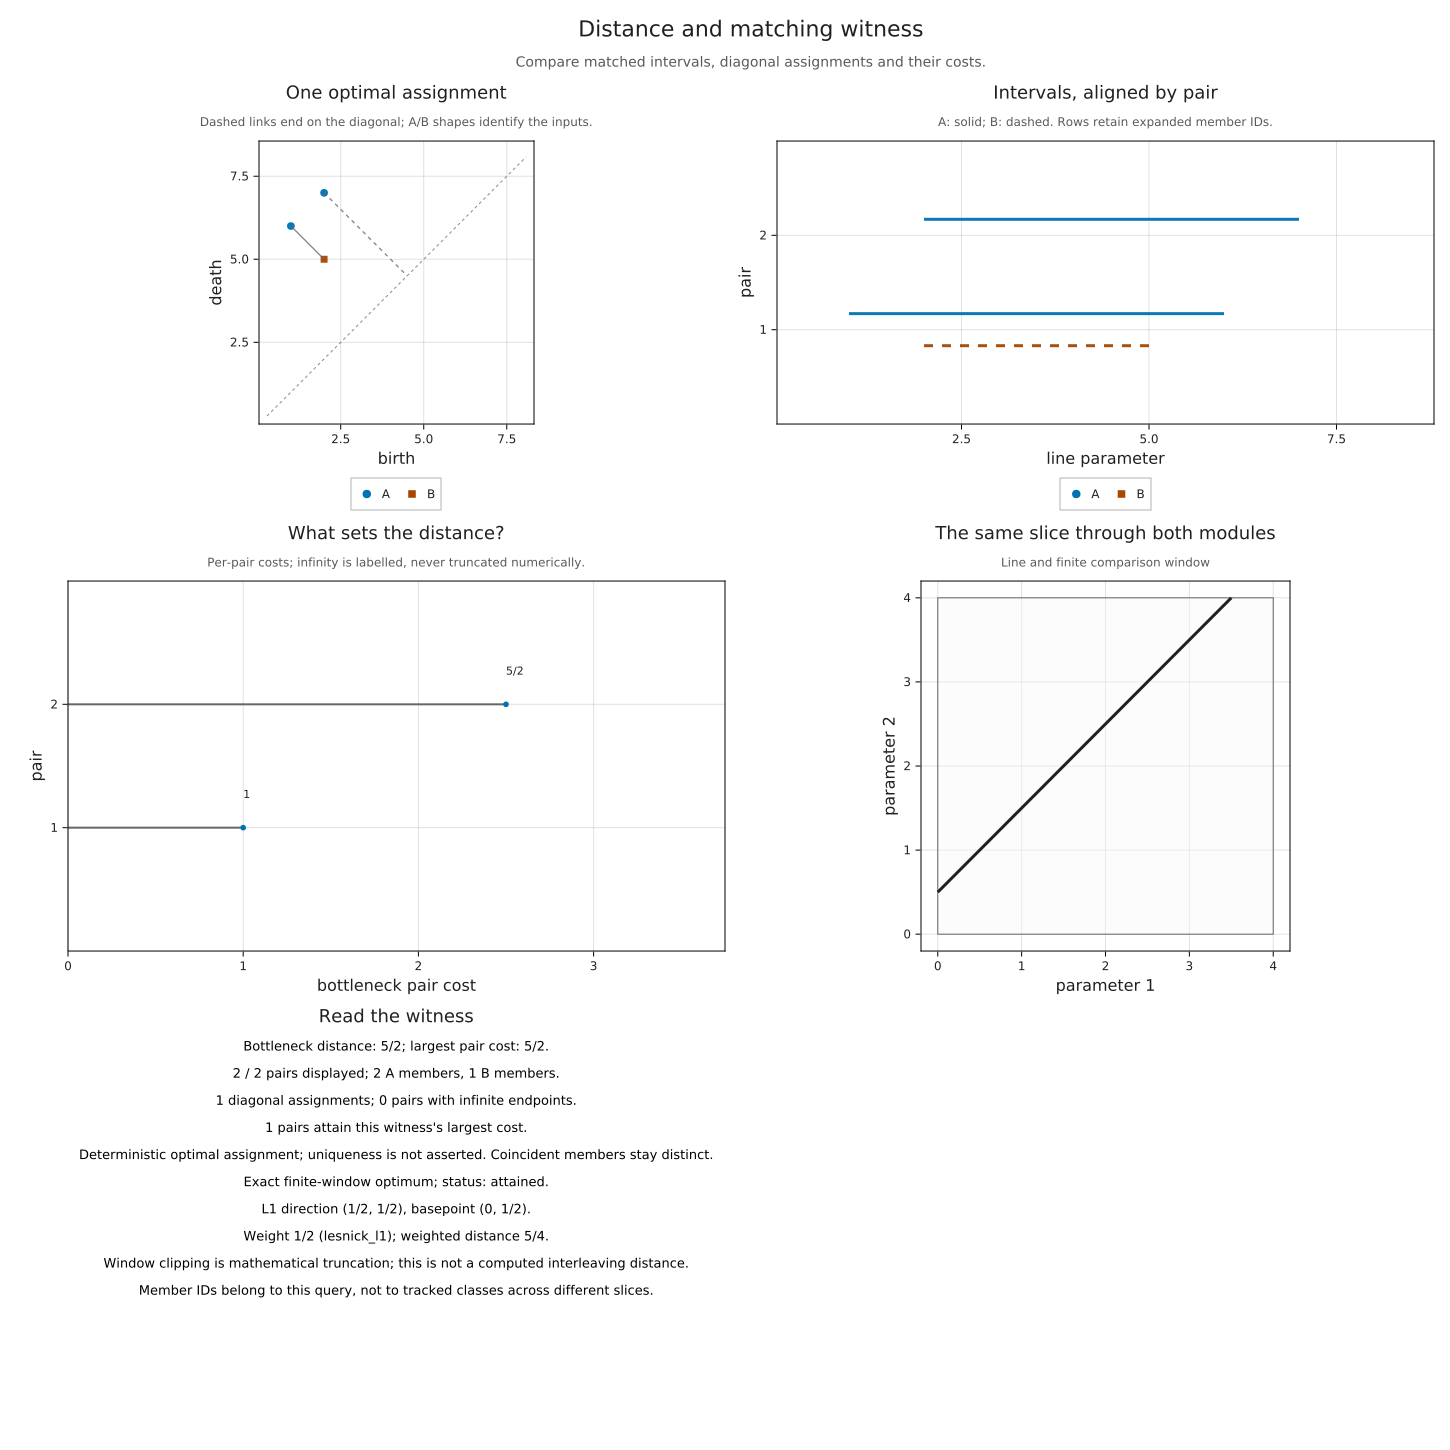
For the rectangle modules constructed below, the optimizing line is $y=x+1/2$. The figure's endpoints use its displayed line parameter, in which the largest pair cost is $5/2$. Multiplying by the slice weight $1/2$ gives the exact weighted answer $5/4$.
For a window of positive area under this solver's hypotheses, the result reports :attained. A window of zero area reports :degenerate_window, with value zero and no asserted maximizing line. These statuses concern the declared finite window. They do not claim an attained maximum for a different, unrestricted problem, and matching distance is not a computed interleaving distance.
Explore before requesting the optimum
A live comparison starts with a diagonal slice and a small map of explicit sample queries. The two encodings must share the same classifier and poset; placing pictures on the same axes does not establish that correspondence.
using WGLMakie
session = OP.inspection_session(encM, encN; opts)
OP.visualize(session; backend=:wglmakie)
Click a diagram point or barcode row to select its pair. The same pair is highlighted in the charts and its exact endpoints and cost appear in the readout. Coincident points cycle through their separate members. A field for the pair ID reaches every retained pair, including those outside the display budget.
Open Compare slices and search the window to select a sample, enter a common positive direction and basepoint, or request the exact window optimum. The default sample family has five angles and three normal offsets per angle. Its map shows discrete costs, without interpolating between samples or certifying an error bound. Best sample chooses the largest of those measured values. The exact button invokes the optimizer with its candidate budget; exhaustion is an error and leaves the previous selection in place.
The distinction matters even on small examples. For two rectangular summands [0,3) × [1,4) and [1,4) × [0,4), compared with [1,3) × [1,3), diagonal lines y = x + h, with 0 ≤ h ≤ 1, give weighted costs
\[\min(1+h/2,\;3/2-h/2).\]
The endpoint samples h=0 and h=1 both give one. Their cost switch at h=1/2 gives 5/4; the order of grid crossings stays fixed there. The graph below shows why sampling only those offsets misses the maximum: the smaller of the two matching costs rises and then falls as the preferable assignment changes.
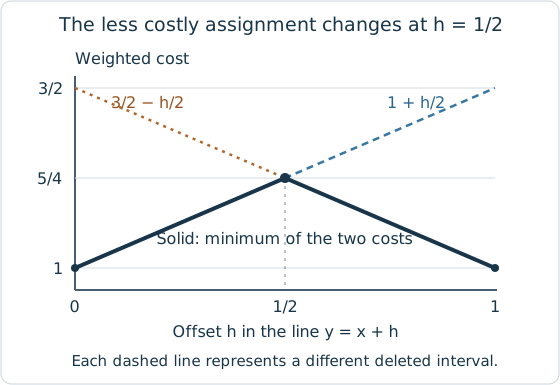
This graph plots the exact formulas for diagonal slices of the rectangle example. Dashed lines show the two candidate assignments; the solid graph is the smaller cost, with its maximum at the crossing.
The same controls are available from Julia:
OA.select_inspection!(session; sample=1)
OA.select_inspection!(session; slice=(basepoint=(0, 1//2), direction=(1, 1)))
OA.select_inspection!(session; optimum=true)
OA.select_inspection!(session; pair=1)
Pair selection and hover reuse the retained assignment. Queries on a selected slice compute only the requested pair of barcodes; the exact optimization is explicit and reused within the session. max_pairs limits the drawing, not the matching. Pass samples=[] when no sample map is wanted, or supply a bounded vector of (basepoint=..., direction=...) queries. Cache inputs share their arrangement's fixed window. OA.inspection_snapshot(session) gives a static exportable view; OA.close_inspection!(session) releases live inputs and callbacks. The live inspector owns its canvas; use the snapshot when composing the selected view into a supplied Makie figure.
Scope and hypotheses
The classifier must be constant on the open cells of its declared axis grid and order preserving, including at coordinate boundaries. Every open cell met by the window must be represented. The two modules must be functors on the same poset over the same field. These are mathematical input hypotheses; the optimizer checks encountered region labels and comparability, but does not prove global functoriality or a custom classifier's correctness.
Box encodings and GridEncodingMap classifiers with increasing axes are supported. A custom classifier must faithfully locate exact interior query points: rational points for rational coordinates, real algebraic points when algebraic coordinates or window endpoints are supplied. A locator that silently rounds those points to Float64 does not meet this contract. Polyhedral classifiers and rounded lattice classifiers are outside this optimizer's scope and are rejected. The coordinate orientations must be positive; see exact grades for expressing rhomboid coordinates as (radius, -depth).
The window has finite, ordered endpoints. A window with zero width or height has value zero. For the rational arrangement route, the window also has to fit its floating query storage; the algebraic coordinate route retains exact window storage. A finite floating coordinate means its represented binary value, not an intended decimal value. Geometry uses Rational{BigInt} or AlgebraicReal, including predicates, intersections and cost comparisons. Linear algebra over the coefficient field retains its separate contract: exact fields give exact barcode ranks; RealField uses its numerical rank policy.
Every essential bar is cut at the window exit. Thus a finite answer is not a claim that the unrestricted matching distance is finite. The windowed and unrestricted quantities agree if the window contains both modules' support. For example, the constant module with one dimensional stalks versus zero has windowed distance min(width, height)/2, although its unrestricted slices have essential bars. Enlarging the window changes the question.
The final conversion to Float64 can lose information. A positive exact result below its representable range can round to zero, and a large finite result can round to infinity. Within that range the result is rounded; the default scalar does not expose a certified interval. With witness=true, OP.describe(result).exact_distance retains the exact optimum before conversion.
Proof of coverage
There are infinitely many lines through the window, so checking a chosen sample would not establish the maximum. The proof below divides the line parameters into finitely many pieces on which both barcode events and matching costs have fixed formulas. It then explains why checking the vertices of those pieces suffices under the preceding hypotheses.
Write the window as [xmin,xmax] × [ymin,ymax], and initially assume positive width and height. In the shallow chart parameterize a line by
y = q*x + h,       0 < q <= 1,
u = q*x,           x = u/q, y = u+h.
The parameter u includes the weight for either supported normalization. Translating its origin translates both barcodes equally and changes no cost. A vertical crossing at x=a has u=q*a; a horizontal crossing at y=b has u=b-h. These are affine functions of (q,h): linear expressions plus a constant.
Keep the order of crossings fixed
Lines meeting the window form the polygon
0 <= q <= 1,
ymin - q*xmax <= h <= ymax - q*xmin.
Include the window sides among the coordinate cuts. Vertical event order is fixed for q>0, as is horizontal event order. Consequently every possible change in event order lies on one of the mixed equalities q*a = b-h. Cutting the polygon by all these equalities fixes the entry event, exit event, and sequence of open cells on each piece with nonempty interior. Window/grid intersections are necessary even when no window corner is a grid vertex. An exact interior point identifies the chain of labels. Its barcode, first expressed in chain indices, is constant throughout the piece; replacing index endpoints by the corresponding events gives affine birth and death functions. Repeated adjacent region labels may be compressed because the corresponding maps are identities.
Keep the ordering of costs fixed
For two finite bars with endpoints $(b,d)$ and $(b',d')$, the cost of pairing them is
max(b - b', b' - b, d - d', d' - d).A bar's diagonal cost is (d-b)/2. Collect all these affine expressions for both barcodes, including zero. Multiplicities give distinct matching vertices even when their endpoint expressions coincide. The augmented bipartite graph has one diagonal copy per bar and a complete block of zero cost edges between diagonal copies, so every allowed partial matching with diagonal deletions is included.
Refine the geometric polygon by every pairwise equality of these affine expressions that crosses its interior. Their ordering is fixed in each resulting open polygon. The largest cost in any fixed perfect matching is therefore one fixed expression there; the smallest such maximum over the finitely many matchings is also one fixed expression. Hence the bottleneck distance is affine on each refined polygon. This accounts for switches both between assignments to another bar and between such assignments and deletion to the diagonal.
Evaluate the vertices of the refined polygons
An affine function on a compact polygon attains a maximum at a vertex. Those vertices are geometric vertices, switch/border intersections or switch/switch intersections. The implementation includes all three. Parallel lines need no intersection; a switch merely touching a vertex or coinciding with a border introduces no new vertex. Exact tests discard intersections outside the polygon. Zero and duplicate costs require no perturbation or tolerance.
Include slices on the boundaries
On a geometric wall, some successive crossing times coalesce. Remove the intervening segments of length zero from a neighboring chain. Functoriality identifies the composite through those segments with the map between the retained endpoints. Thus the rank invariant, and hence the barcode after zero length intervals have been removed, is that of this coarsened chain. Approaching the wall from either neighboring polygon gives this same barcode after deleting bars of length zero. A value supported only at the crossing time is ephemeral and has zero bottleneck cost. This explains why evaluating neighboring affine formulas on their closures gives the correct boundary value; it is not an assumption about a floating locator's choice of labels at boundaries. It also explains why order preservation and module functoriality are essential hypotheses. At a line tangent to the window, all clipped bars have zero length.
Include limiting directions and steep slopes
Every bar in the shallow chart has weighted lifespan at most q*(xmax-xmin). Deleting all bars bounds the distance by half that number, so the q=0 limit is zero uniformly in offset. Swap the axes and repeat to cover slopes greater than or equal to one and the other axis limit. The diagonal occurs in both charts. The two compactified charts and their vertices therefore cover the entire stated supremum.
This argument applies over the rational and real algebraic ordered fields: all constructed coordinates, affine intersections and comparisons stay exact. The finite algorithm terminates if its work budget permits it.
A module pair whose maximum needs a cost switch
Let I(R) denote the rectangle interval module, with identity maps within the rectangle and zero maps outside it. Endpoint inclusion does not affect the bottleneck values below. In the window [0,4] × [0,4], take
M = I([0,3] × [1,4]) ⊕ I([1,4] × [0,4]),
N = I([1,3] × [1,3]).
Their exact weighted matching distance is 5/4. To see the upper bound, parameterize any positive line in weighted units as x=a*t, y=b*t+h, with a,b>=1 and min(a,b)=1. The rectangle of N lies in both rectangles of M. Each endpoint moves by at most one weighted unit on passing from either M interval to the N interval: the relevant coordinate differences are at most one and the divisors a,b are at least one. Whenever the N interval is present, matching it to either M interval therefore costs at most one.
If the M intervals have lengths l1,l2, their endpoint formulas give
l1 <= 3/a - (1-h)/b,
l2 <= (4-h)/b - 1/a,
l1 + l2 <= 2/a + 3/b <= 5.
Match N to the longer interval and delete the shorter one, at cost at most max(1, (l1+l2)/4) <= 5/4. If N is absent, each existing M interval has length at most two by the same bounds on endpoint displacements, so deleting them costs at most one.
On the diagonal line y=x+1/2, the diagrams are
M: [1/2,3], [1,7/2],
N: [1,5/2].
At least one M interval must be deleted, costing 5/4; matching the other to N costs at most one. This attains the bound. More generally, on y=x+h, 0<=h<=1, the exact distance is min(1+h/2, 3/2-h/2). Its maximum at h=1/2 switches which M interval is deleted. No integer grid event coincides on this line: the order and identity of its barcode events remain fixed in a neighborhood. The diagonal belongs to both slope charts used by the implementation, while it lies in the interior of the space of lines of positive slope. An optimizer that only checks changes in the order of geometric crossings would therefore miss the change of optimal assignment that produces this maximum.
The following constructs those same half-open rectangles with rational coefficients. Each rectangle has a one dimensional space at its active labels and identity maps between them. Both encodings use one grid classifier and poset, so their slice coordinates are already comparable.
<!– BEGIN exactmatchingexample –>
import TamerOp as OP
using CairoMakie
const OA = OP.Advanced
QQ = Rational{BigInt}
coordinates = QQ[0, 1, 3, 4]
P = OA.ProductOfChainsPoset((4, 4))
classifier = OA.GridEncodingMap(P, (coordinates, coordinates))
rectangles = [((0,1), (3,4)), ((1,0), (4,4)), ((1,1), (3,3))]
summands = map(rectangles) do (lo, hi)
    dimensions = [Int(lo[1] <= x < hi[1] && lo[2] <= y < hi[2])
                  for y in coordinates for x in coordinates]
    maps = Dict((a,b) => fill(one(QQ), dimensions[b], dimensions[a])
                for (a,b) in OA.cover_edges(P))
    OA.PModule{QQ}(P, dimensions, maps; field=OP.CoreModules.QQField())
end
encM = OP.EncodingResult(P, OA.direct_sum(summands[1], summands[2]), classifier)
encN = OP.EncodingResult(P, summands[3], classifier)
Keep the witness to compare its exact answer with the bound just proved. The weighted assignment cost must agree with that answer, and its line must have slope one and intercept one half.
opts = OA.InvariantOptions(box=([0,0], [4,4]), threads=false)
result = OP.matching_distance_exact_2d(encM, encN; opts, witness=true)
query = OA.slice_query(result)
assignment = OA.matching_witness(result)
@assert OP.describe(result).exact_distance == 5//4
@assert query.weight * assignment.distance == 5//4
@assert query.direction[1] == query.direction[2]
@assert query.basepoint[2] - query.basepoint[1] == 1//2
OP.visualize(result)
<!– END exactmatchingexample –>
Literature and limits
Critical barcode events alone do not determine the maximum: optimal matching switches also matter, as explained by Brooks et al., Switch Points of Bi-Persistence Matching Distance. Bjerkevik and Kerber's exact algorithm uses arrangements and a decision procedure with different complexity bounds. The implementation here is an exhaustive affine refinement for the finite window and hypotheses on classifier cells proved above. It does not implement either paper's complete algorithm or claim their asymptotic performance.
max_candidates conservatively charges geometric splits, barcode expansion, cost pairs and intersection pairs, including rejected intersections. Exceeding it throws rather than returning a partial or sampled maximum. The arrangement has a separate max_cells budget. These are combinatorial work guards, not bounds on elapsed time or peak memory. Pass cache=session with a retained SessionCache() to reuse the arrangement and cached module barcodes in chain indices across compatible encoding queries. The optimizer's exact geometric cells and cost switches for the pair of modules are rebuilt for each exact call. Use the explicit sampled API for exploratory queries when this exhaustive optimizer is too costly.